Two-Finger Robot Grippers: Why a Simple Design Remains So Useful

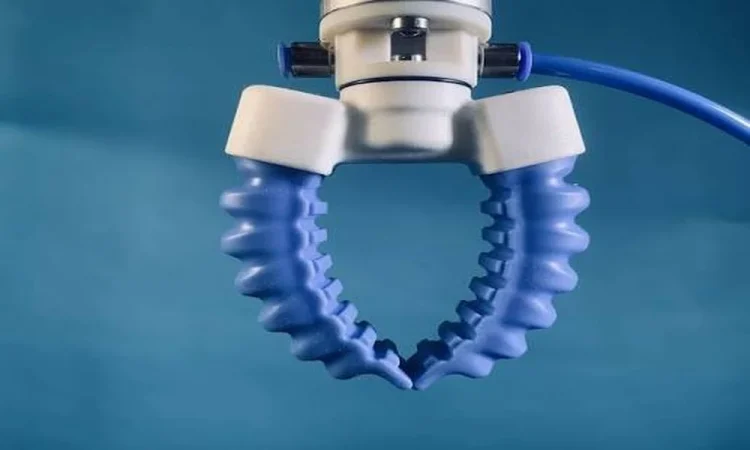
The parallel two-finger gripper is one of the most familiar tools in industrial robotics. Its basic principle is uncomplicated: two opposing fingers move toward or away from each other to hold a workpiece. Despite that simplicity, the design can be used in a surprisingly wide range of applications.Machine tending, pick-and-place...